1. Check the servos
so101-doctor reads the settings of your six servos and warns about the ones that are off. It cannot move the arm or change a setting.
Released Install and run it. Free, Apache-2.0.
Software that makes a $200 robot arm go where it is told. First release: so101-doctor, a free servo check and simulated twin for the SO-101 arm.
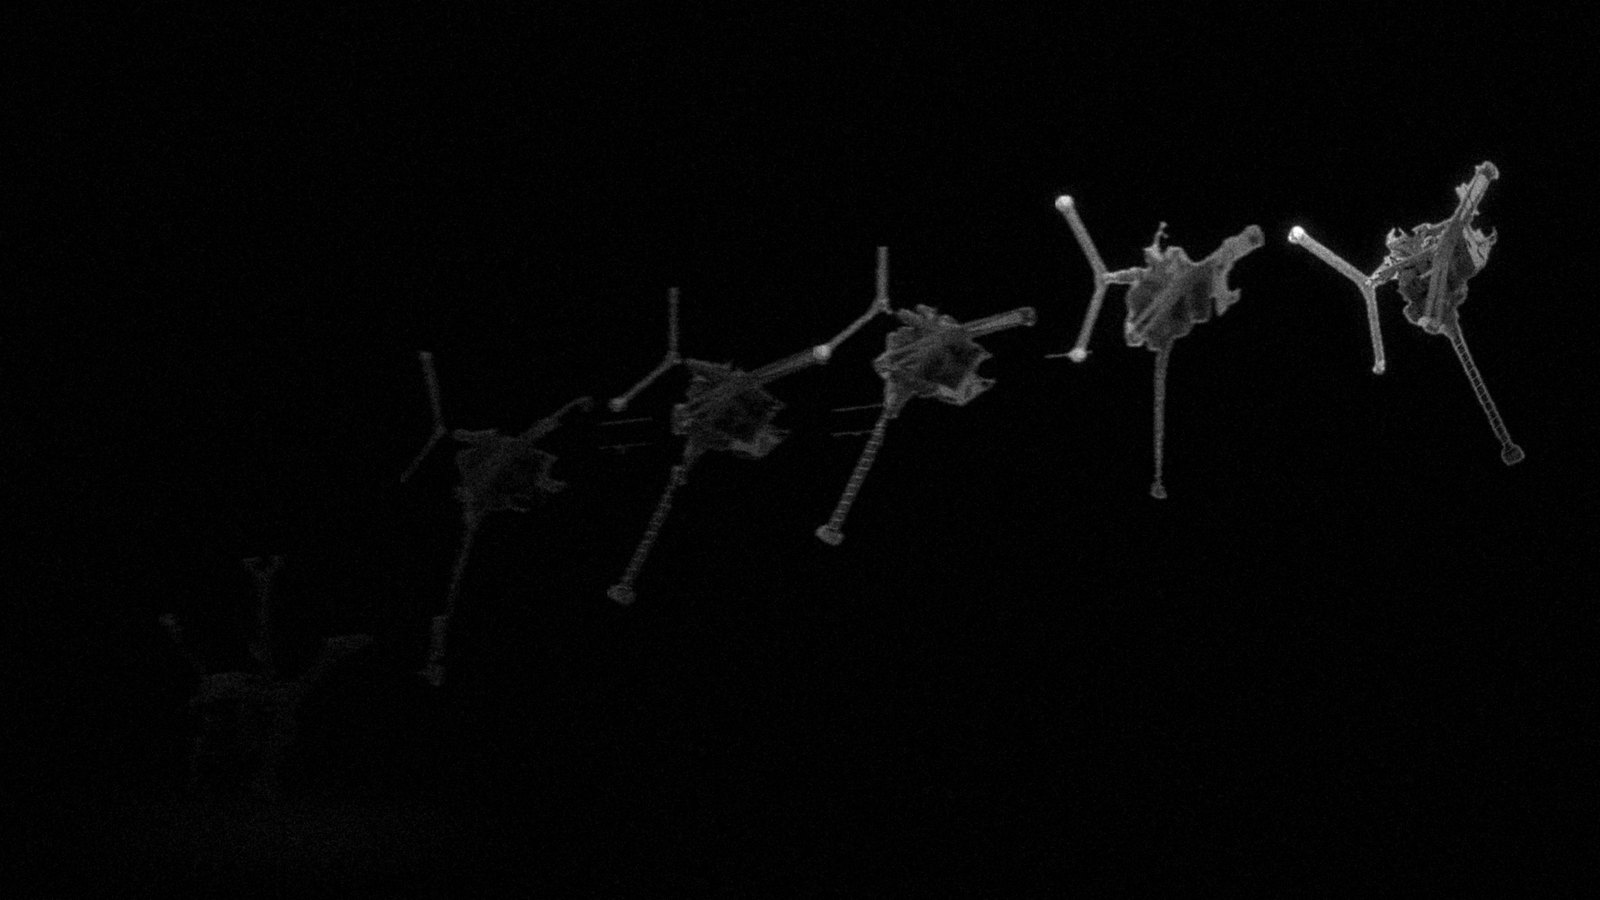
Get so101-doctorMRV jumping robot, built by hand. Frames from one jump.
CommandServoPeak lag
Simulated from datasheet limits; 10 ms delay assumed. Not a measurement.
so101-doctor reads the settings of your six servos and warns about the ones that are off. It cannot move the arm or change a setting.
Released Install and run it. Free, Apache-2.0.
A MuJoCo twin (a simulated copy) of the SO-101 with the servo’s real control loop. It rests about twice as close to the real arm as the stock model.
| Arm set to | Twin | Stock model |
|---|---|---|
| P 16 | 6.4 mm | 15.2 mm |
| P 32 | 3.7 mm | 7.7 mm |
| One arm, nothing in the gripper, from the joint encoders. 180 holds on 8 Nov 2026 (P 16), 164 on 10 Nov 2026 (P 32). Stock model: MuJoCo Menagerie. The twin and its limits. | ||
Released Not yet replicated It comes with so101-doctor.
A twin of your own arm, fitted from a short recording session, used to make the real arm more precise.
| Measure | Result |
|---|---|
| Tip error with 200 g at the jaw | 5.1× lower |
| Measured by camera at a tag on the gripper. One arm, one session, 9 Nov 2026. | |
In progress Not yet replicated Not released. Request early access
Payload and contact force from the servos’ own load readings, with no added sensor.
In progress Early access, by request. Request early access
| Item | Project | Area | Year | Picture |
|---|---|---|---|---|
| 1 | so101-doctor | Servo check, MuJoCo twin | 2026 |  |
| 2 | Rocky Robotics, 1st place | Quarry autonomy | 2026 | |
| 3 | 3D room change detection | Perception | 2026 | 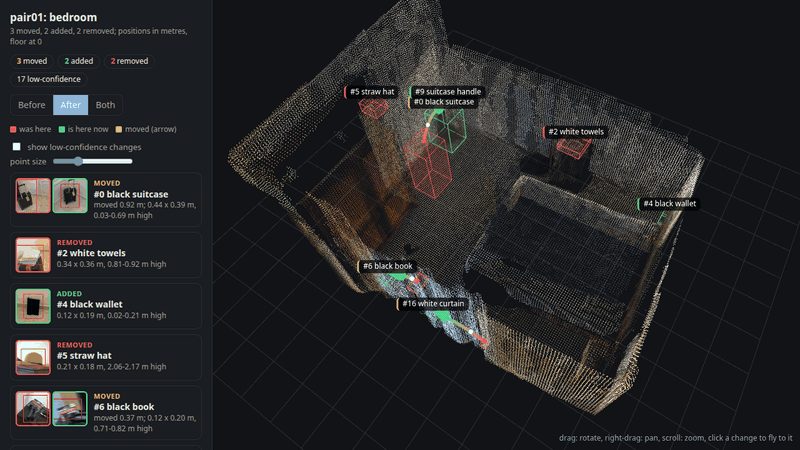 |
| 4 | Phone-to-robot learning | Imitation learning | 2026 | |
| 5 | Reaction-wheel pendulum | Control, LQR vs PPO | 2026 | 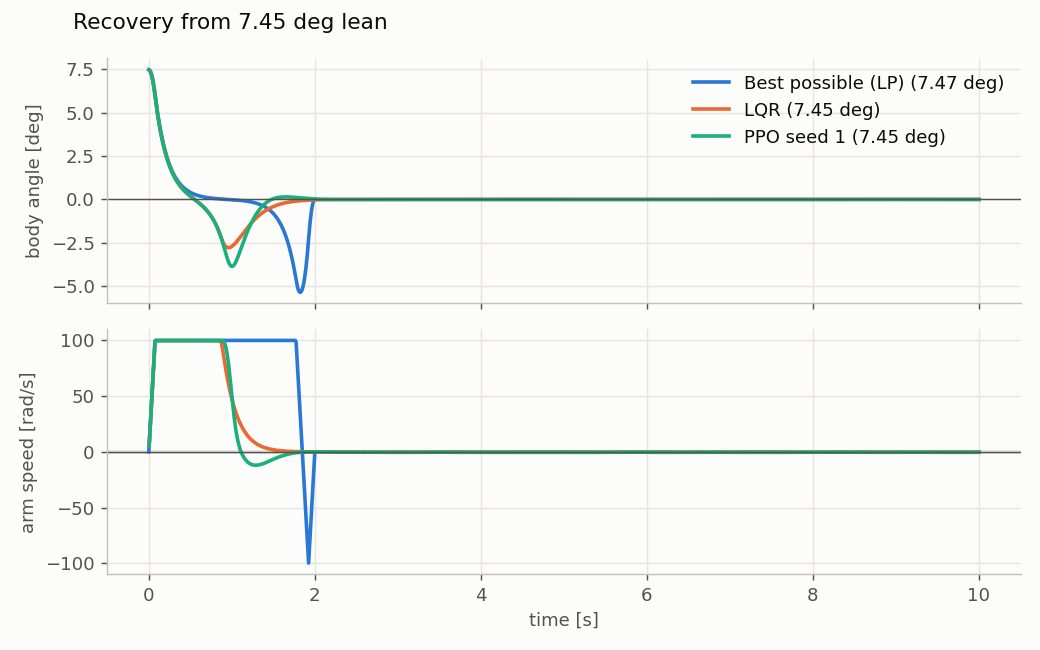 |
| 6 | MRV jumping robot | Hardware, dissertation | 2026 | 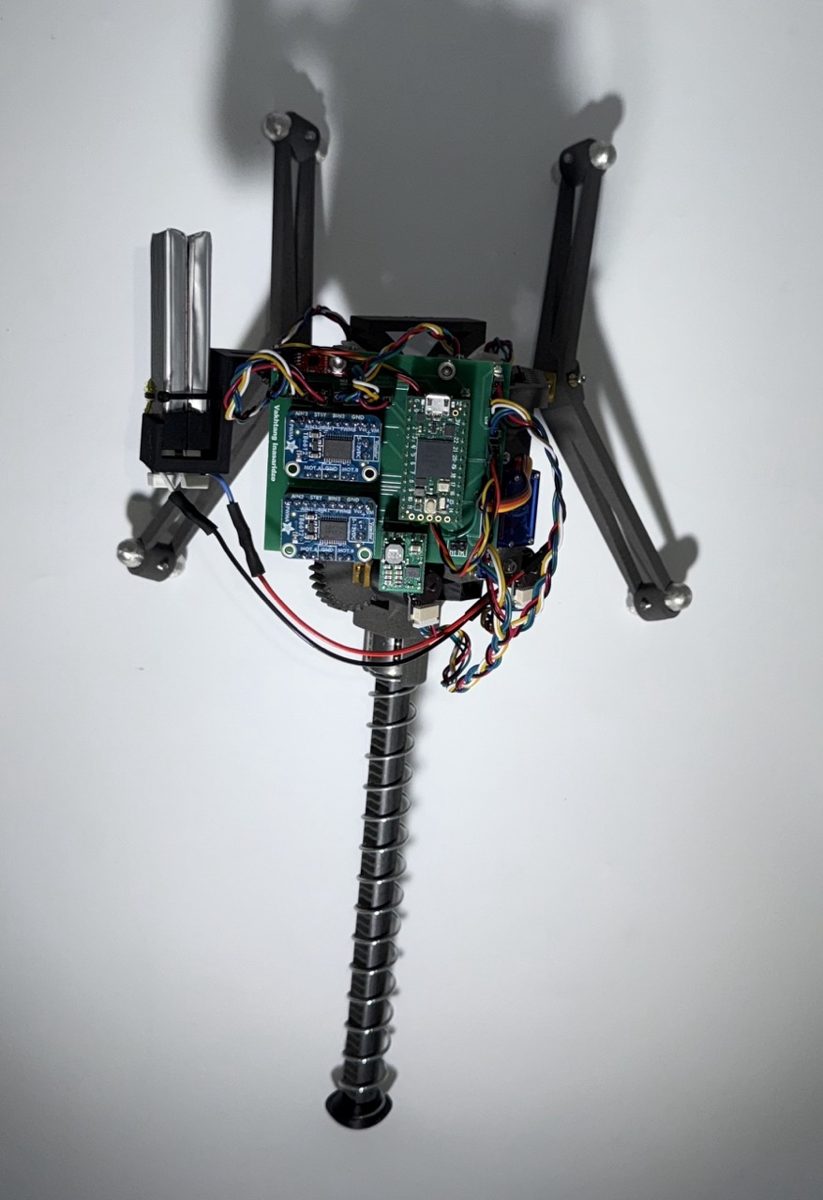 |
| 7 | Cannulation trainer | Medical device | BEng |
Before software, hardware: the last robot here was designed, printed, wired and cast from scratch, and it jumps 41 cm.
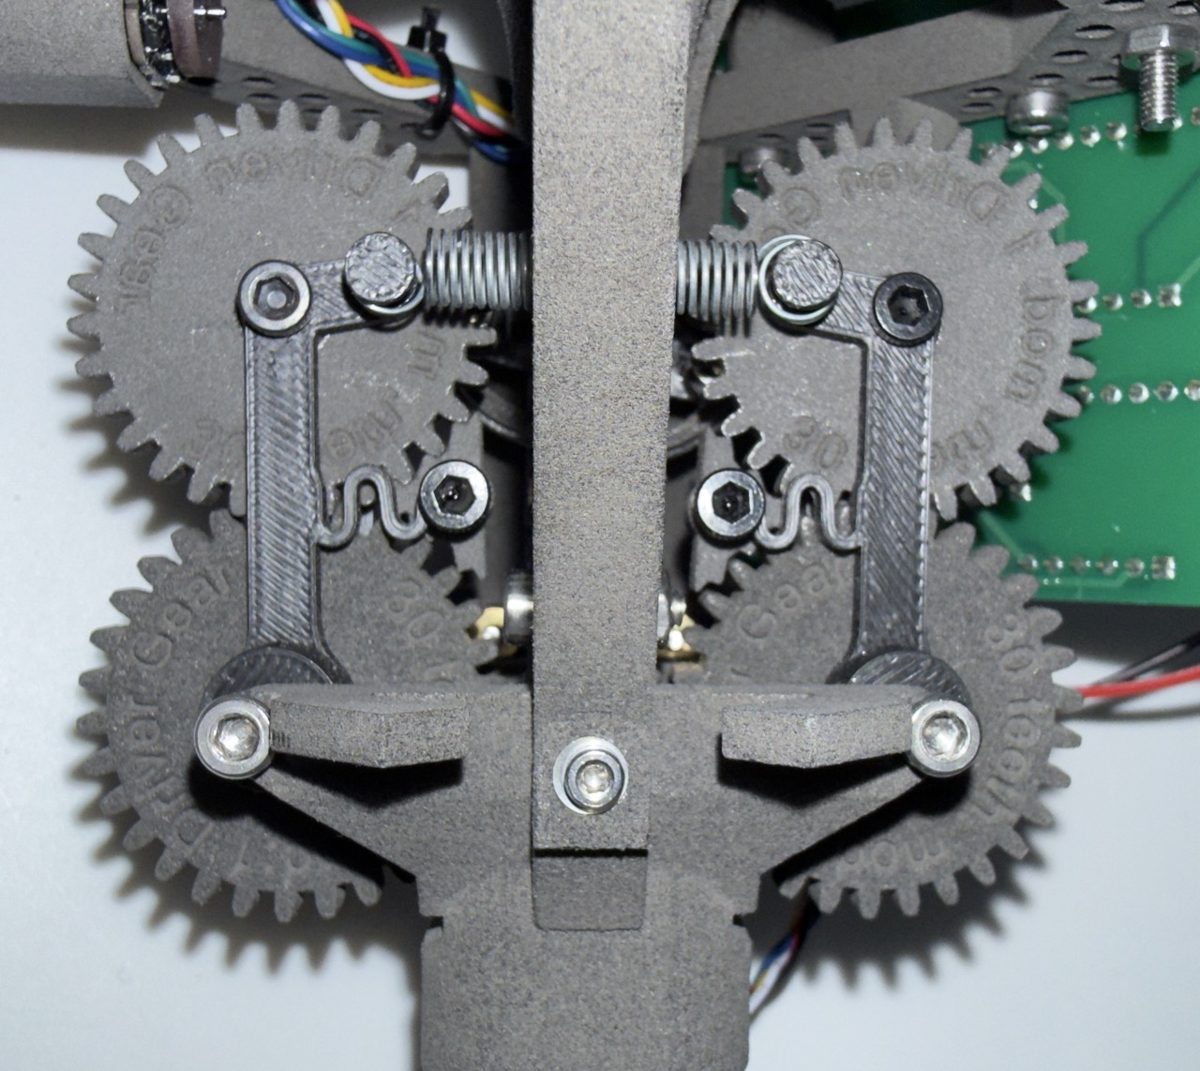
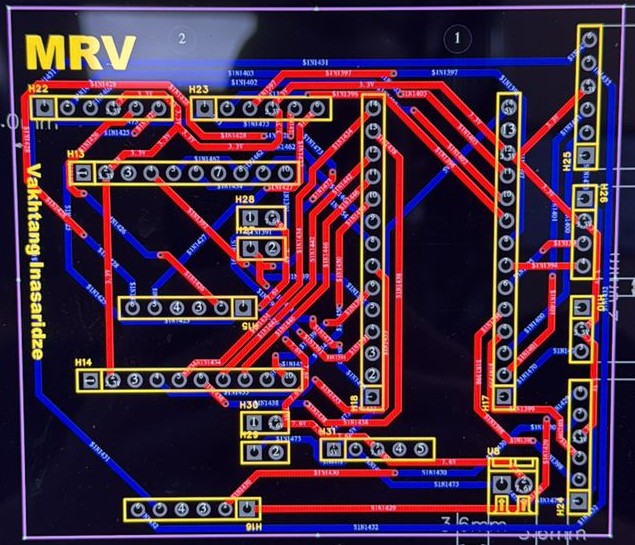
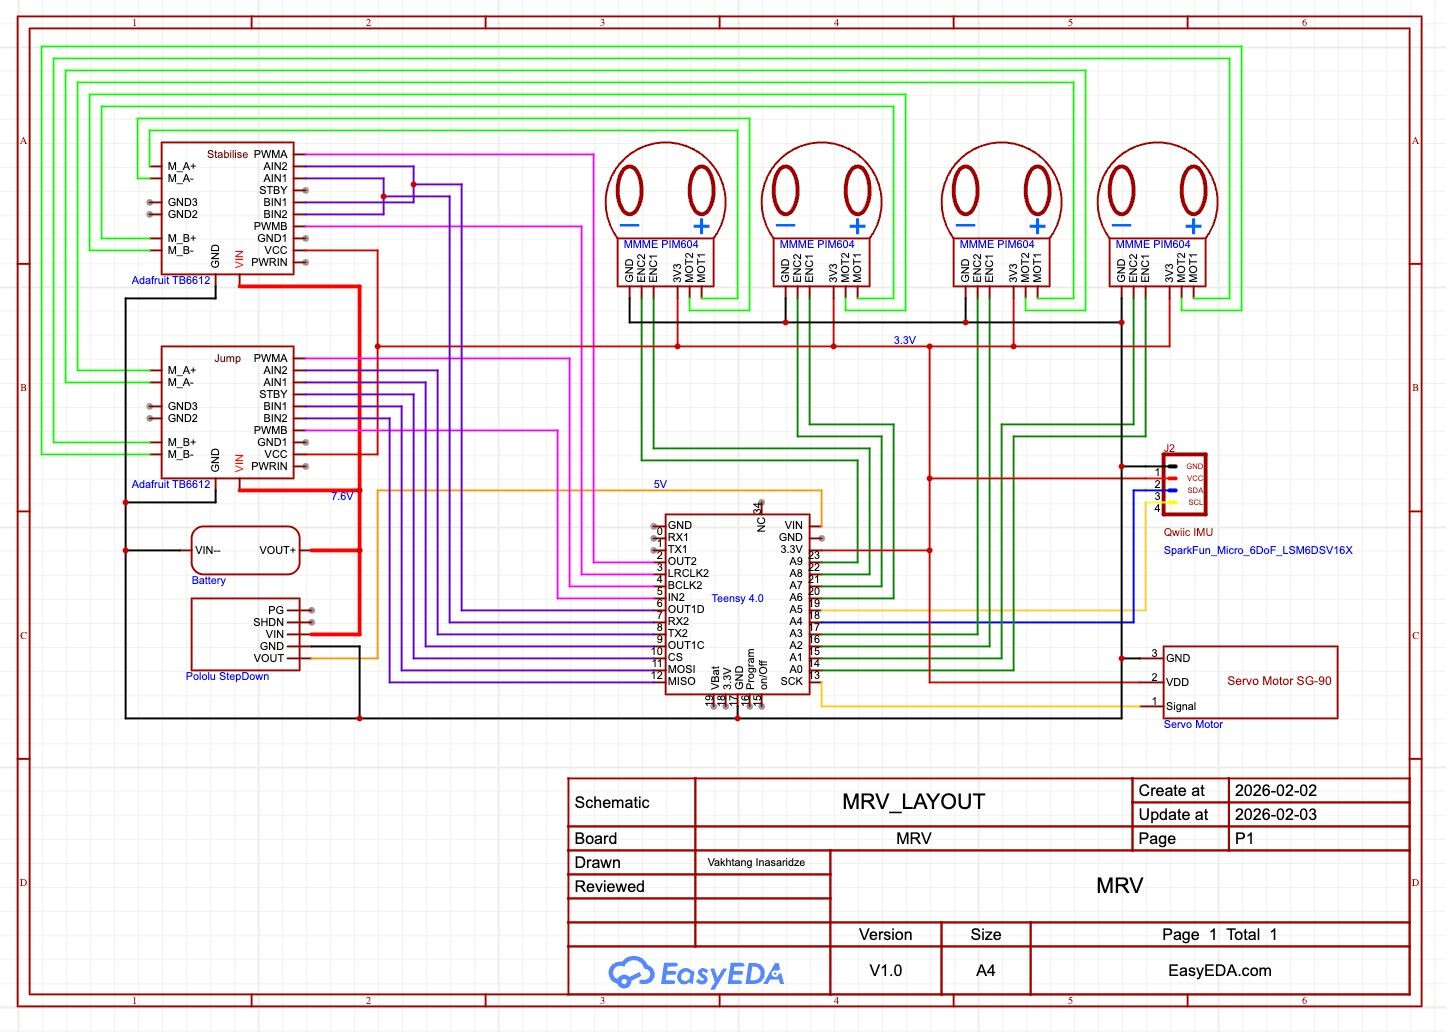
I’m Vato. I studied mechanical engineering at Warwick and start an MEng at Berkeley in Fall 2027. Until then, I’m building this.
Cheap robot arms are good enough to do real work. What holds them back is that their servos are rarely modelled, so the arm doesn’t go where the policy tells it to.
The goal: a $200 arm makes my breakfast every morning, learned from a video of my own hands. That needs an arm that goes exactly where it is told, so that is where I’m starting.
Every result here comes with its trial count, its failures and its cost. If it breaks, you’ll see it break.
Vato Inasaridze
Founder, Vato Labs. inasaridzevato@gmail.com
| Entry | Date |
|---|---|
| so101-doctor released: a read-only servo check for the SO-101 and a MuJoCo twin for arms at P 16 or P 32 | |
| Twin checked on the arm at P 32: tip 3.7 mm from the real one, 7.7 mm for the stock model (164 holds, not yet replicated) | |
| First per-arm calibration result: tip error with 200 g at the jaw 5.1× lower, by camera (one session, not yet replicated) | |
| Twin checked on the arm at P 16: tip 6.4 mm from the real one, 15.2 mm for the stock model (180 holds, not yet replicated) | |
| Bench servo: BAM’s servo model with the firmware’s acceleration profile, simulation error 18.1 to 7.1 mrad (method and credits) | |
| Calibration motions tested in sim: twins agree within 0.2°, so real servo data is the next lever | |
| Servo twin fitted on public 12 V logs: 0.8° error on unseen moves, vs 8.3° with ready-made params | |
| Lab set up: printer calibrated, servo fit gauges printed, robot station configured | |
| 1st place of 60 builders, Physical AI Hack London | |
| Top 8 of about 180, Accel AI Innovate London |